Differential Geometry
Geometric descriptions of configuration, motion, and interaction.
Robotics · control · autonomous systems
Geometric control, vehicle-manipulator systems, autonomous robotics, and safe physical human-robot interaction. I am a phd student in Systems and Control Engineering at King Fahd University of Petroleum & Minerals.
Current Research
Development of control frameworks for integrated vehicle-manipulator platforms with focus on safe physical interaction
Open theme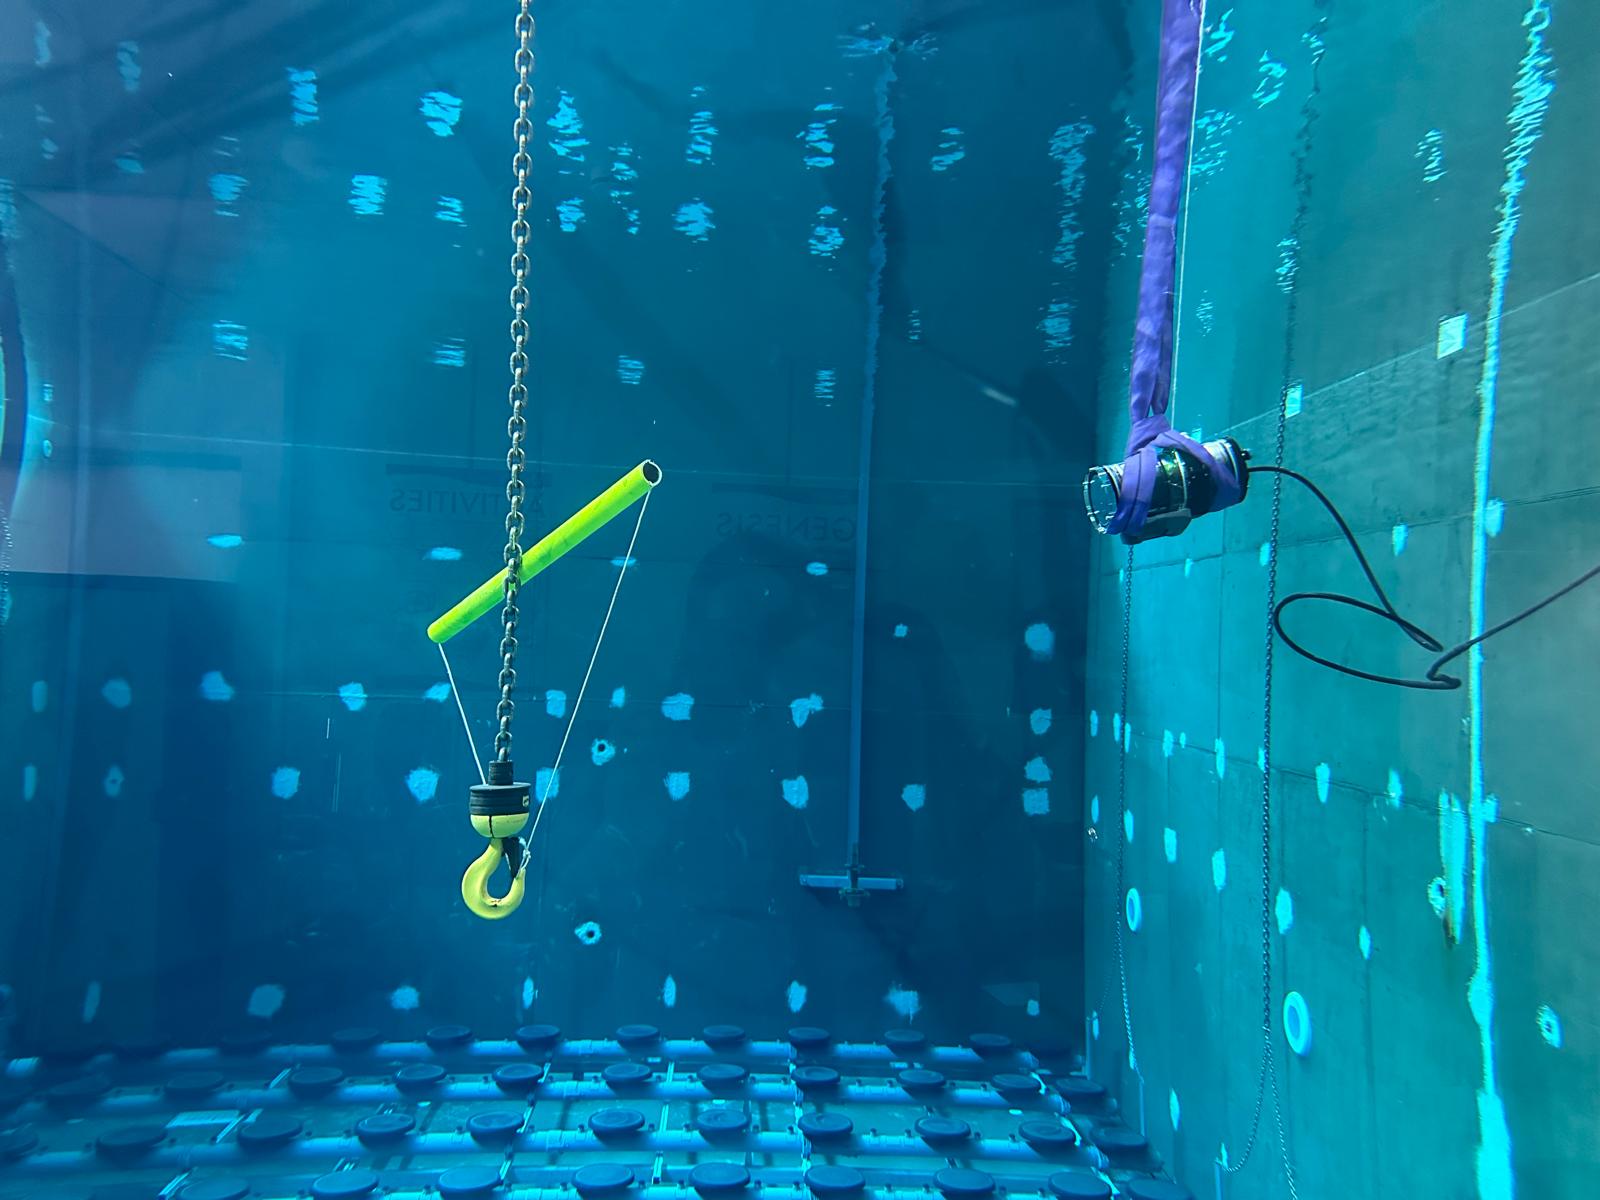
Geometric descriptions of configuration, motion, and interaction.
Structure-preserving models and energy-aware control design.
Control methods for reliable physical human–robot interaction.
Latest publication
Published work and submissions are collected in the publication record.
Farooq Olanrewaju, Aymen Benyahia, Ramy Rashad, Sami El-Ferik