Vehicle-Manipulator Systems
Development of control frameworks for integrated vehicle-manipulator platforms with focus on safe physical interaction
Open themeResearch
A working catalogue of research across geometric modelling, autonomous systems, and physical interaction.
Current research
Each record names the problem, its period, and the methods currently shaping the work.
Development of control frameworks for integrated vehicle-manipulator platforms with focus on safe physical interaction
Open theme
Ongoing modelling and control of a Voliro-like aerial robot model, with emphasis on geometric dynamics, estimation, and control allocation.
Open themeCompleted work
Earlier projects remain useful context for the methods and systems I work with today.
Control and estimation projects spanning renewable-energy management and probabilistic robotic perception.
Open theme
A marine-robotics portfolio spanning MSc projects and ship-system identification work across Université de Toulon, Instituto Superior Técnico, and Universitat Jaume I.
Open theme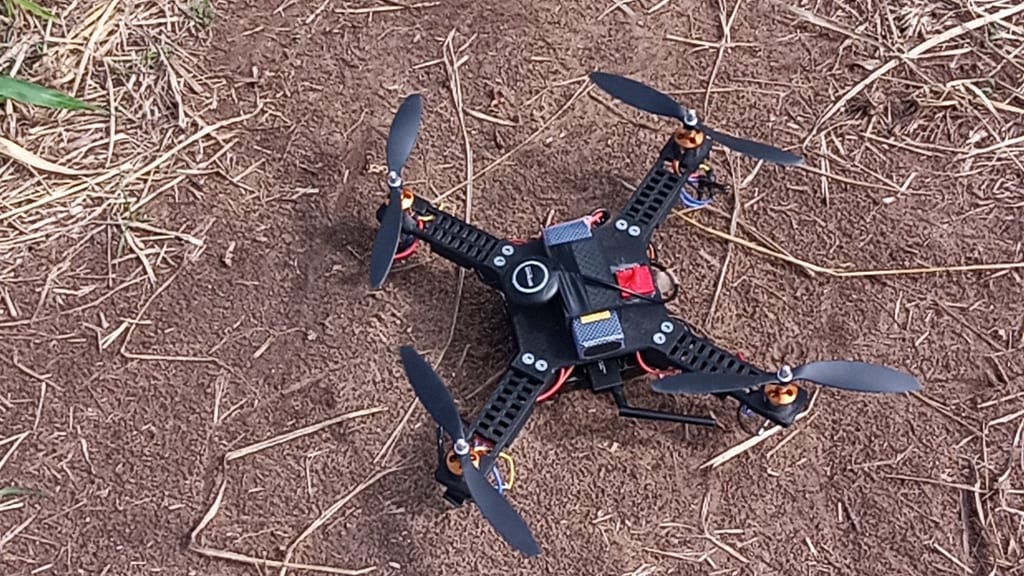
Undergraduate thesis project covering quadcopter CAD design, fabrication, preliminary structural analysis, and basic flight control.
Open theme