Research theme

Marine Robotics

A marine-robotics portfolio spanning MSc projects and ship-system identification work across Université de Toulon, Instituto Superior Técnico, and Universitat Jaume I.

2022 - 2025CompletedMarine Robotics · Underwater Robotics · Ship Identification

MSc project portfolio

This theme brings together the marine-robotics work completed during my Erasmus Mundus Master’s degree in Marine and Maritime Intelligent Robotics, together with subsequent ship-system identification work. It spans three universities and combines modelling, autonomous underwater vehicle control, oceanographic analysis, underwater perception, docking, cooperative manipulation, and maritime computer vision.

The projects were completed across Université de Toulon (UTLN), France; Instituto Superior Técnico (IST), Portugal; and Universitat Jaume I (UJI), Spain. Together, they trace a progression from understanding marine environments and modelling underwater vehicles to implementing autonomy and grasp planning on robotic platforms.

Project areas

  • Autonomous underwater vehicle modelling and simulation
  • Oceanographic data analysis for the Mediterranean Sea
  • BlueROV trajectory planning, control, docking, and search tasks
  • Vision-based perception for underwater interaction
  • Grasp planning for cooperative underwater robots
  • Automated ship identification and classification from satellite imagery
  • Optimization-driven system identification of ship maneuvering dynamics

Each project is listed below with its institution context, period, technical focus, and available repository or thesis material.
Project portfolio

Projects within this theme.

Selected work, methods, and outputs across the marine-robotics portfolio.

Illustration of a ship crossing a measured horizon with identification traces
Sep 2024 – Dec 2024completed

Model-based ARX Ship Identification

APO-optimized ARX-based system identification of ship maneuvering systems, later published in 2025.

Python · Control Systems · System Identification

View publication ↗
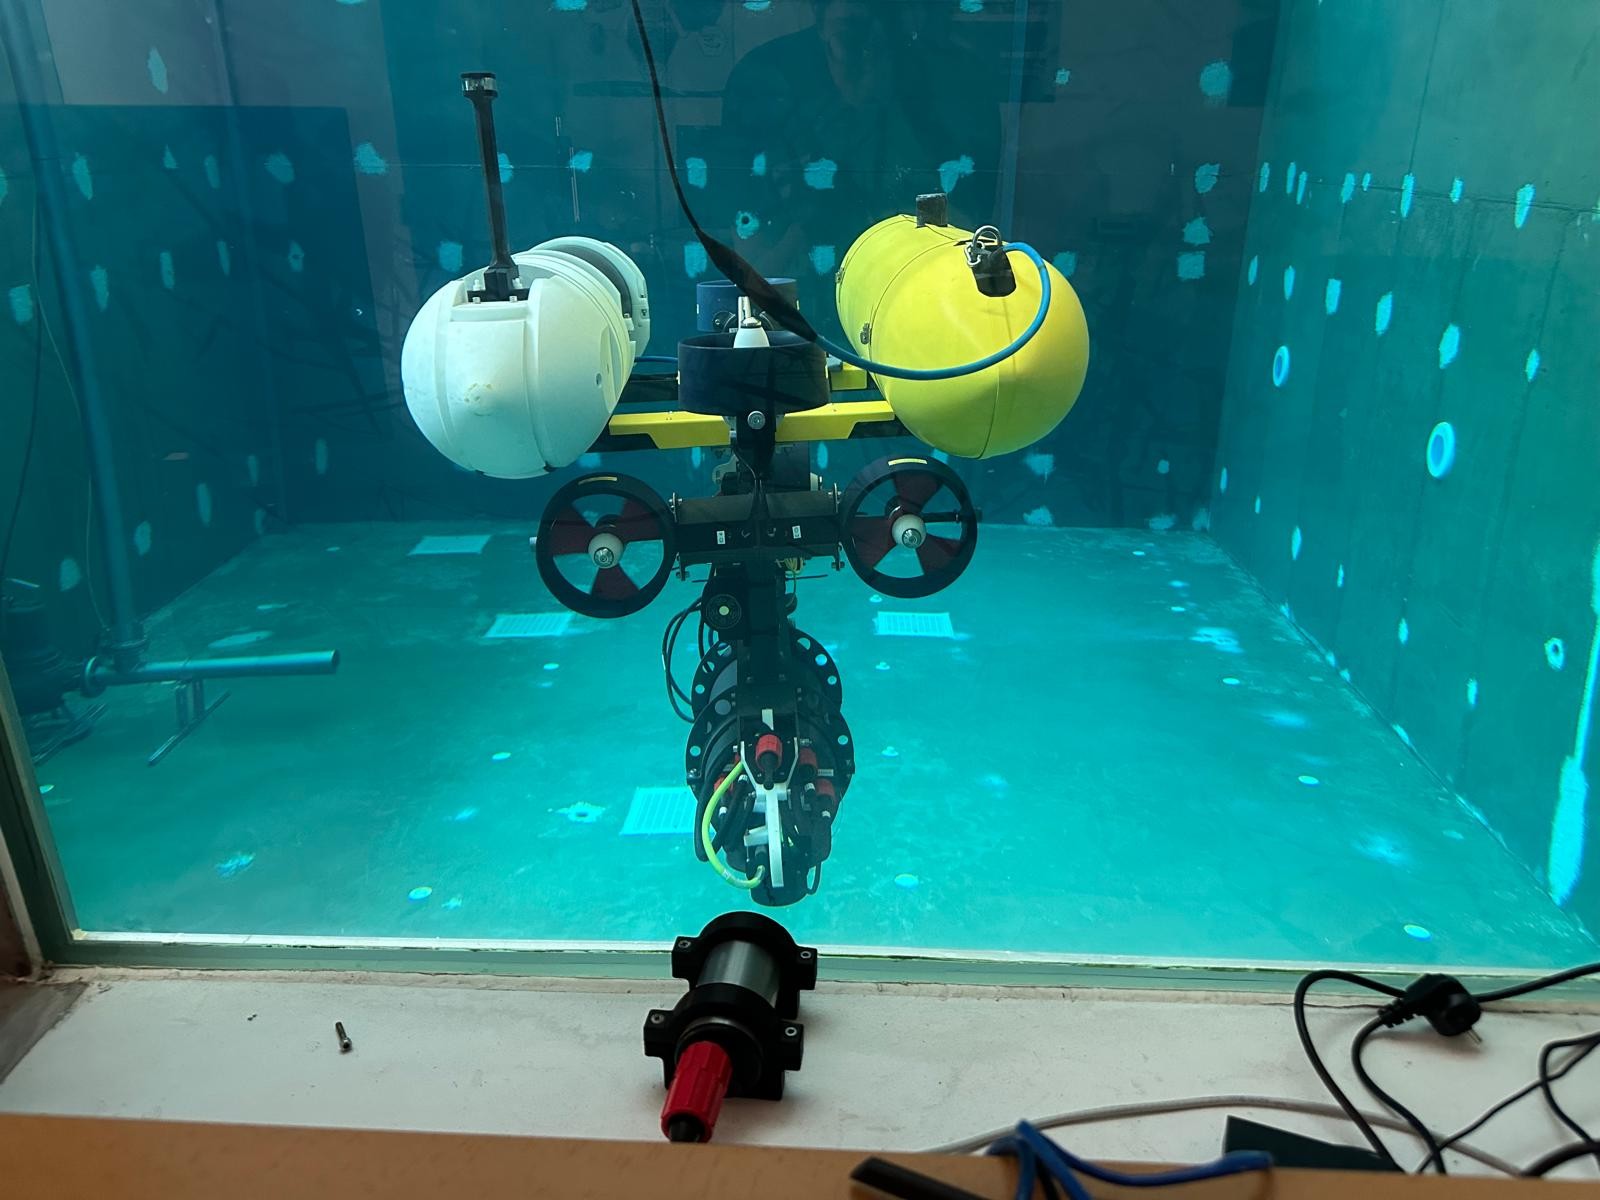
Underwater robot positioned in a test tank
Feb 2024 – Jun 2024completed

Grasp Planning for Underwater Robot Cooperation

Master's thesis research at Universitat Jaume I as part of the COOPERAMOS project on underwater robot cooperation.

Python · ROS · Computer Vision

View project ↗
Underwater test tank with a robotic manipulator and suspended object
Mar 2023 – Jun 2023completed

Autonomous Docking and Underwater Treasure Search

Vision-based autonomous systems for an underwater robotics competition with BlueROV.

Python · ROS · Deep Learning

View project ↗
Underwater robot positioned in a test tank
Feb 2023 – May 2023completed

Trajectory Planning and Autonomous Control

Path planning and control algorithms for BlueROV autonomous underwater vehicles.

Python · ROS · Planning

View project ↗
Underwater test tank prepared for marine robotics experiments
Oct 2022 – Feb 2023completed

Oceanographic Analysis of the Mediterranean Sea

Data-driven analysis and visualization of oceanographic data from the Mediterranean Sea.

MATLAB · Python · Data Analysis

View project ↗
Underwater test tank prepared for marine robotics experiments
Oct 2022 – Jan 2023completed

Modelling and Simulation of Autonomous Underwater Vehicle

System dynamics modelling and simulation of underwater robotic systems.

MATLAB · Simulink · Dynamics

View project ↗

Publication record

Published and submitted work connected to this research direction.

2025Published

APO-Optimized ARX-Based System Identification of a Ship Maneuvering System

Farooq Olanrewaju, Md. Shafiullah, Mujahed Al-Dhaifallah, Muslim Alaran

2025 IEEE 22nd International Multi-Conference on Systems, Signals & Devices (SSD)PublisherDOIBibTeX